Nav2 Smac Planner
The Smac Planner is the family of search-based planners in Nav2, the ROS 2 navigation stack used by thousands of robots in industry and research.
Why it matters
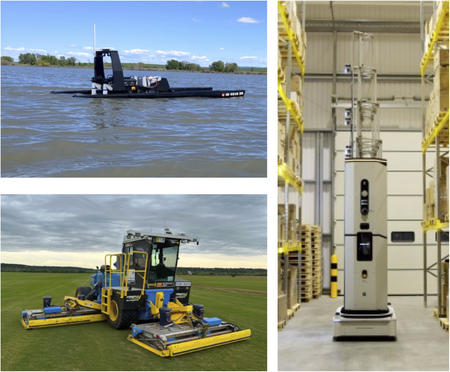
Robots such as car-like vehicles, legged platforms and surface vessels cannot simply turn on the spot. The Smac Planner produces paths that respect each robot’s kinematics while accounting for costs in the environment, and it is fast enough for real-time use. Our paper in IEEE Robotics and Automation Practice with the Nav2 maintainers documents its design and evaluates it on mobile and surface robots.