Open Source
A defining feature of my research leadership has been building the software infrastructure that accelerates global robotics research, from running ROS on every platform to reproducible environments and benchmarks.
35k+RoboStack downloads worldwide
500+GitHub stars each for RoboStack and VSLAM-LAB
Nav2co-author of the Smac Planner in the ROS 2 navigation stack
Pixicontributor and lead author of the Pixi paper
Projects
RoboStack
The Robot Operating System on conda-forge, for Linux, macOS and Windows alike.
Learn More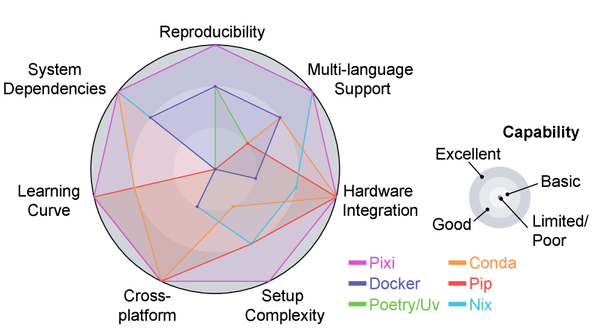
Pixi
Unified, reproducible software development and distribution for robotics and AI.
Learn More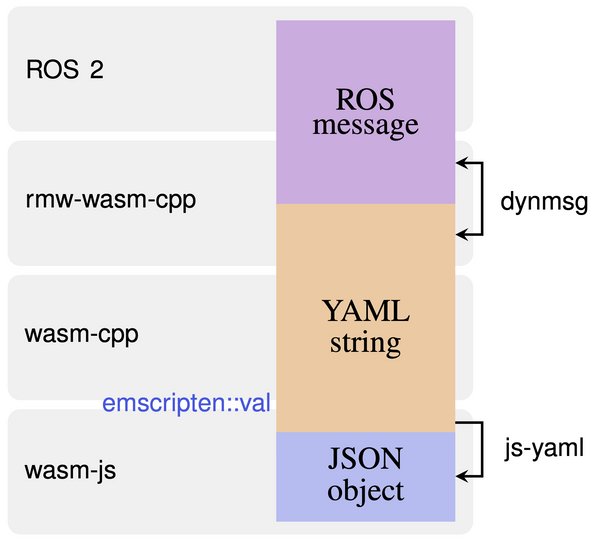
ROS2WASM
The Robot Operating System running entirely in the web browser.
Learn More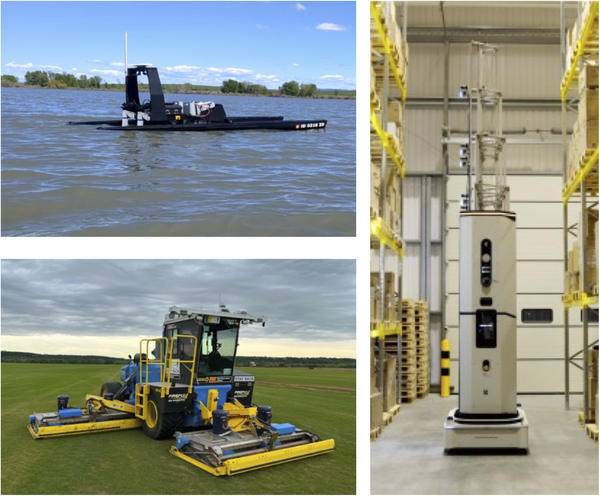
Nav2 Smac Planner
Open-source, cost-aware, kinematically feasible path planning for mobile and surface robots.
Learn More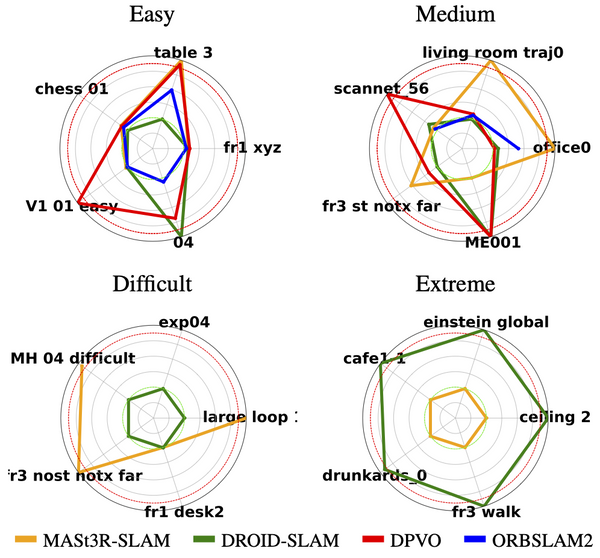
VSLAM-LAB, Event-LAB and EventCV
Frameworks that make visual SLAM and event-based methods easy to run, compare and reproduce.
Learn More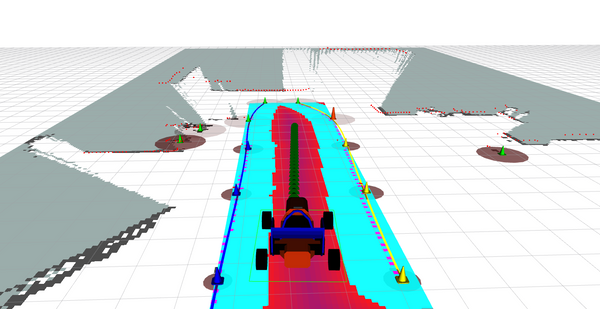
Autonomous Racing with ROS 2
A ROS 2 navigation system for an autonomous Formula Student race car, built with QUT Motorsport.
Learn More