Open source · 500+ GitHub stars

VSLAM-LAB, Event-LAB and EventCV

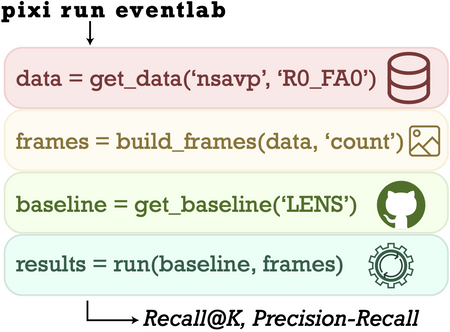
Fair comparisons need consistent tooling. We build open frameworks that install, run and evaluate dozens of methods and datasets with a single command.

Why it matters

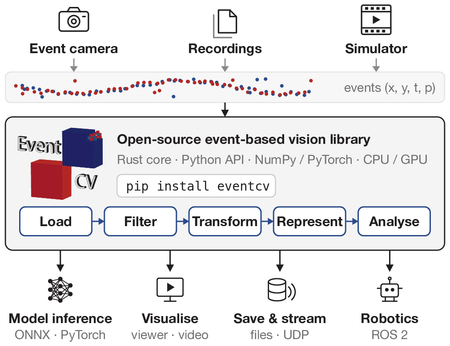
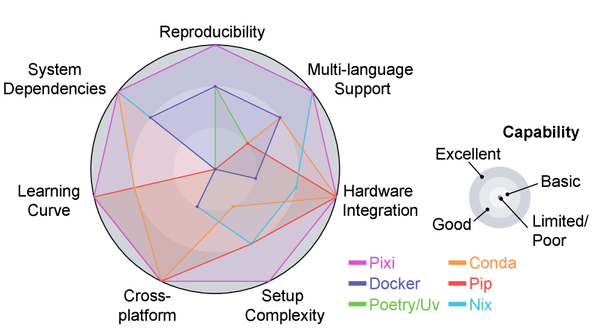
VSLAM-LAB (500+ GitHub stars) wraps visual SLAM methods and datasets behind a common interface, using Pixi for reproducible environments. Event-LAB brings the same idea to neuromorphic localisation, and the EventCV library provides building blocks for event-based robotic vision.

Team

Members of my group at the QUT Centre for Robotics and close collaborators.
Tobias Fischer Tobias Fischer
Lead
Alejandro Fontan Alejandro Fontan
Collaborator
Adam Hines Adam Hines
Former postdoc

Publications

Selected papers from this line of work. See all publications.

arXiv 2026

The EventCV Library for Event-Based Robotic Vision

Adam D. Hines, Michael Milford, and Tobias Fischer

arXiv 2609.21330

ICRA 2026

Event-LAB: Towards Standardized Evaluation of Neuromorphic Localization

Adam D Hines, Alejandro Fontan, Michael Milford, and Tobias Fischer

IEEE International Conference on Robotics and Automation 2026

IROS 2025

VSLAM-LAB: A Comprehensive Framework for Visual SLAM Methods and Datasets

Alejandro Fontan, Tobias Fischer, Javier Civera, and Michael Milford

IEEE/RSJ International Conference on Intelligent Robots and Systems 2025

arXiv 2024

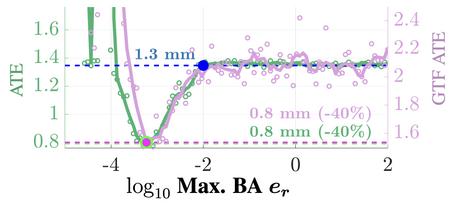
Look Ma, No Ground Truth! Ground-Truth-Free Tuning of Structure from Motion and Visual SLAM

Alejandro Fontan, Javier Civera, Tobias Fischer, and Michael Milford

arXiv 2412.01116