ROS2WASM
ROS2WASM compiles ROS 2 to WebAssembly, so robotics software runs in a browser tab with nothing to install.
Why it matters
Zero-install ROS makes it far easier to teach robotics, share reproducible demos, and connect web interfaces directly to robots. ROS2WASM runs ROS 2 nodes, topics and services inside the browser and builds on RoboStack’s conda-forge packages.
More projects
RoboStack
The Robot Operating System on conda-forge, for Linux, macOS and Windows alike.
Learn More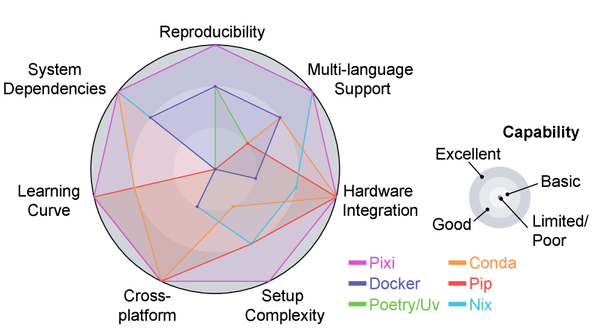
Pixi
Unified, reproducible software development and distribution for robotics and AI.
Learn More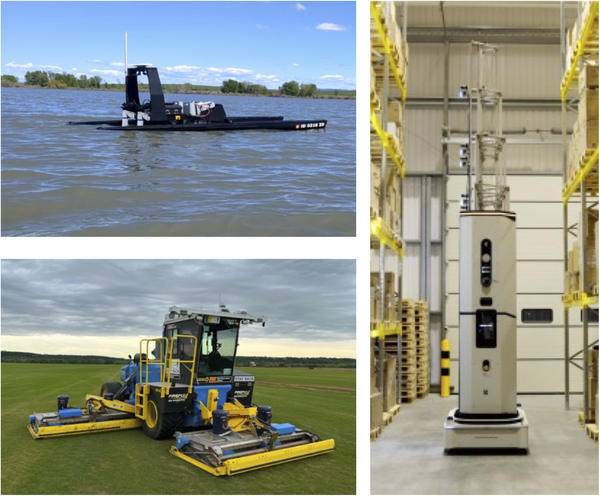
Nav2 Smac Planner
Open-source, cost-aware, kinematically feasible path planning for mobile and surface robots.
Learn More