Bio-inspired Navigation
Animals navigate reliably with tiny energy budgets. We borrow their strategies for robots.
Why it matters
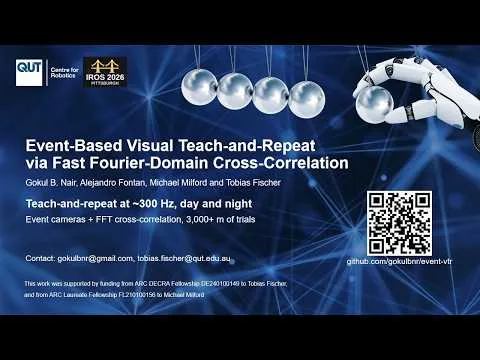
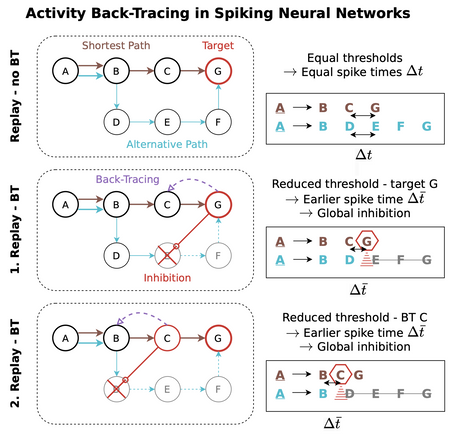
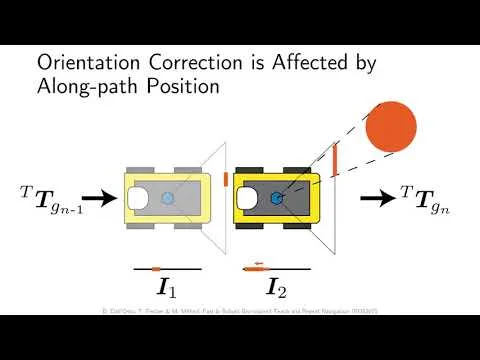
Teach-and-repeat lets a robot retrace a route it was shown once, using only a camera. Our bio-inspired approach is fast and robust, we have paired it with robust control, and it now runs on event cameras for high-speed, low-latency route following. Continuous attractor networks, modelled on the brain’s grid and head-direction cells, let us track trajectories across multiple scales, and threshold adaptation in spiking networks enables shortest-path finding and place disambiguation.
Team
Members of my group at the QUT Centre for Robotics and close collaborators.
Lead
 Michael Milford
Collaborator
Former PhD student
Former postdoc
PhD student
Former postdoc
 Alejandro Fontan
Collaborator
More projects
Brain-Inspired Positioning for Fast, Energy-Efficient, Resilient Robotics
The world’s first sub-millisecond, energy-efficient robot positioning system, using brain-inspired sensing and computation that only happens when the scene changes.
Learn More
Adaptive and Efficient Robot Positioning Through Model and Task Fusion
Fit-for-purpose positioning systems that continuously adapt to diverse and changing environments, and are energy efficient enough for edge devices.
Learn More
Neuromorphic Place Recognition
Spiking neural networks that recognise places on neuromorphic hardware, using a fraction of the usual energy.
Learn More